Amber Li

Hi! I am a third year Ph.D. student in the Robotics Institute at Carnegie Mellon University. I am fortunate to be advised by Professors David Held and Maxim Likhachev. Previously I received my B.S. and M.Eng. in computer science from MIT, where I was a part of the Learning and Intelligent Systems Group and worked with Tom Silver, advised by Leslie Kaelbling.

I have also spent some time as a software engineer at Two Sigma. In my free time, I enjoy running, reading, and playing the violin. I have also dabbled in dance.

Email  /  Resume  /  Scholar  /  Twitter  /  Github

profile photo

Research

I'm broadly interested in creating intelligent embodied agents that can learn and act in dynamic environments over long time horizons. Recently, I've been investigating how we can efficiently plan and adapt robot policies and/or world models based on observed outcomes.

Long-Horizon Multi-Object Rearrangement via Distilled Tree Search over Continuous Actions
Kallol Saha, Yining Hong, Amber Li, Yejin Choi, Maxim Likhachev, David Held
Conference on Robot Learning (CoRL) 2026 (Oral presentation, Top 1%)
project page

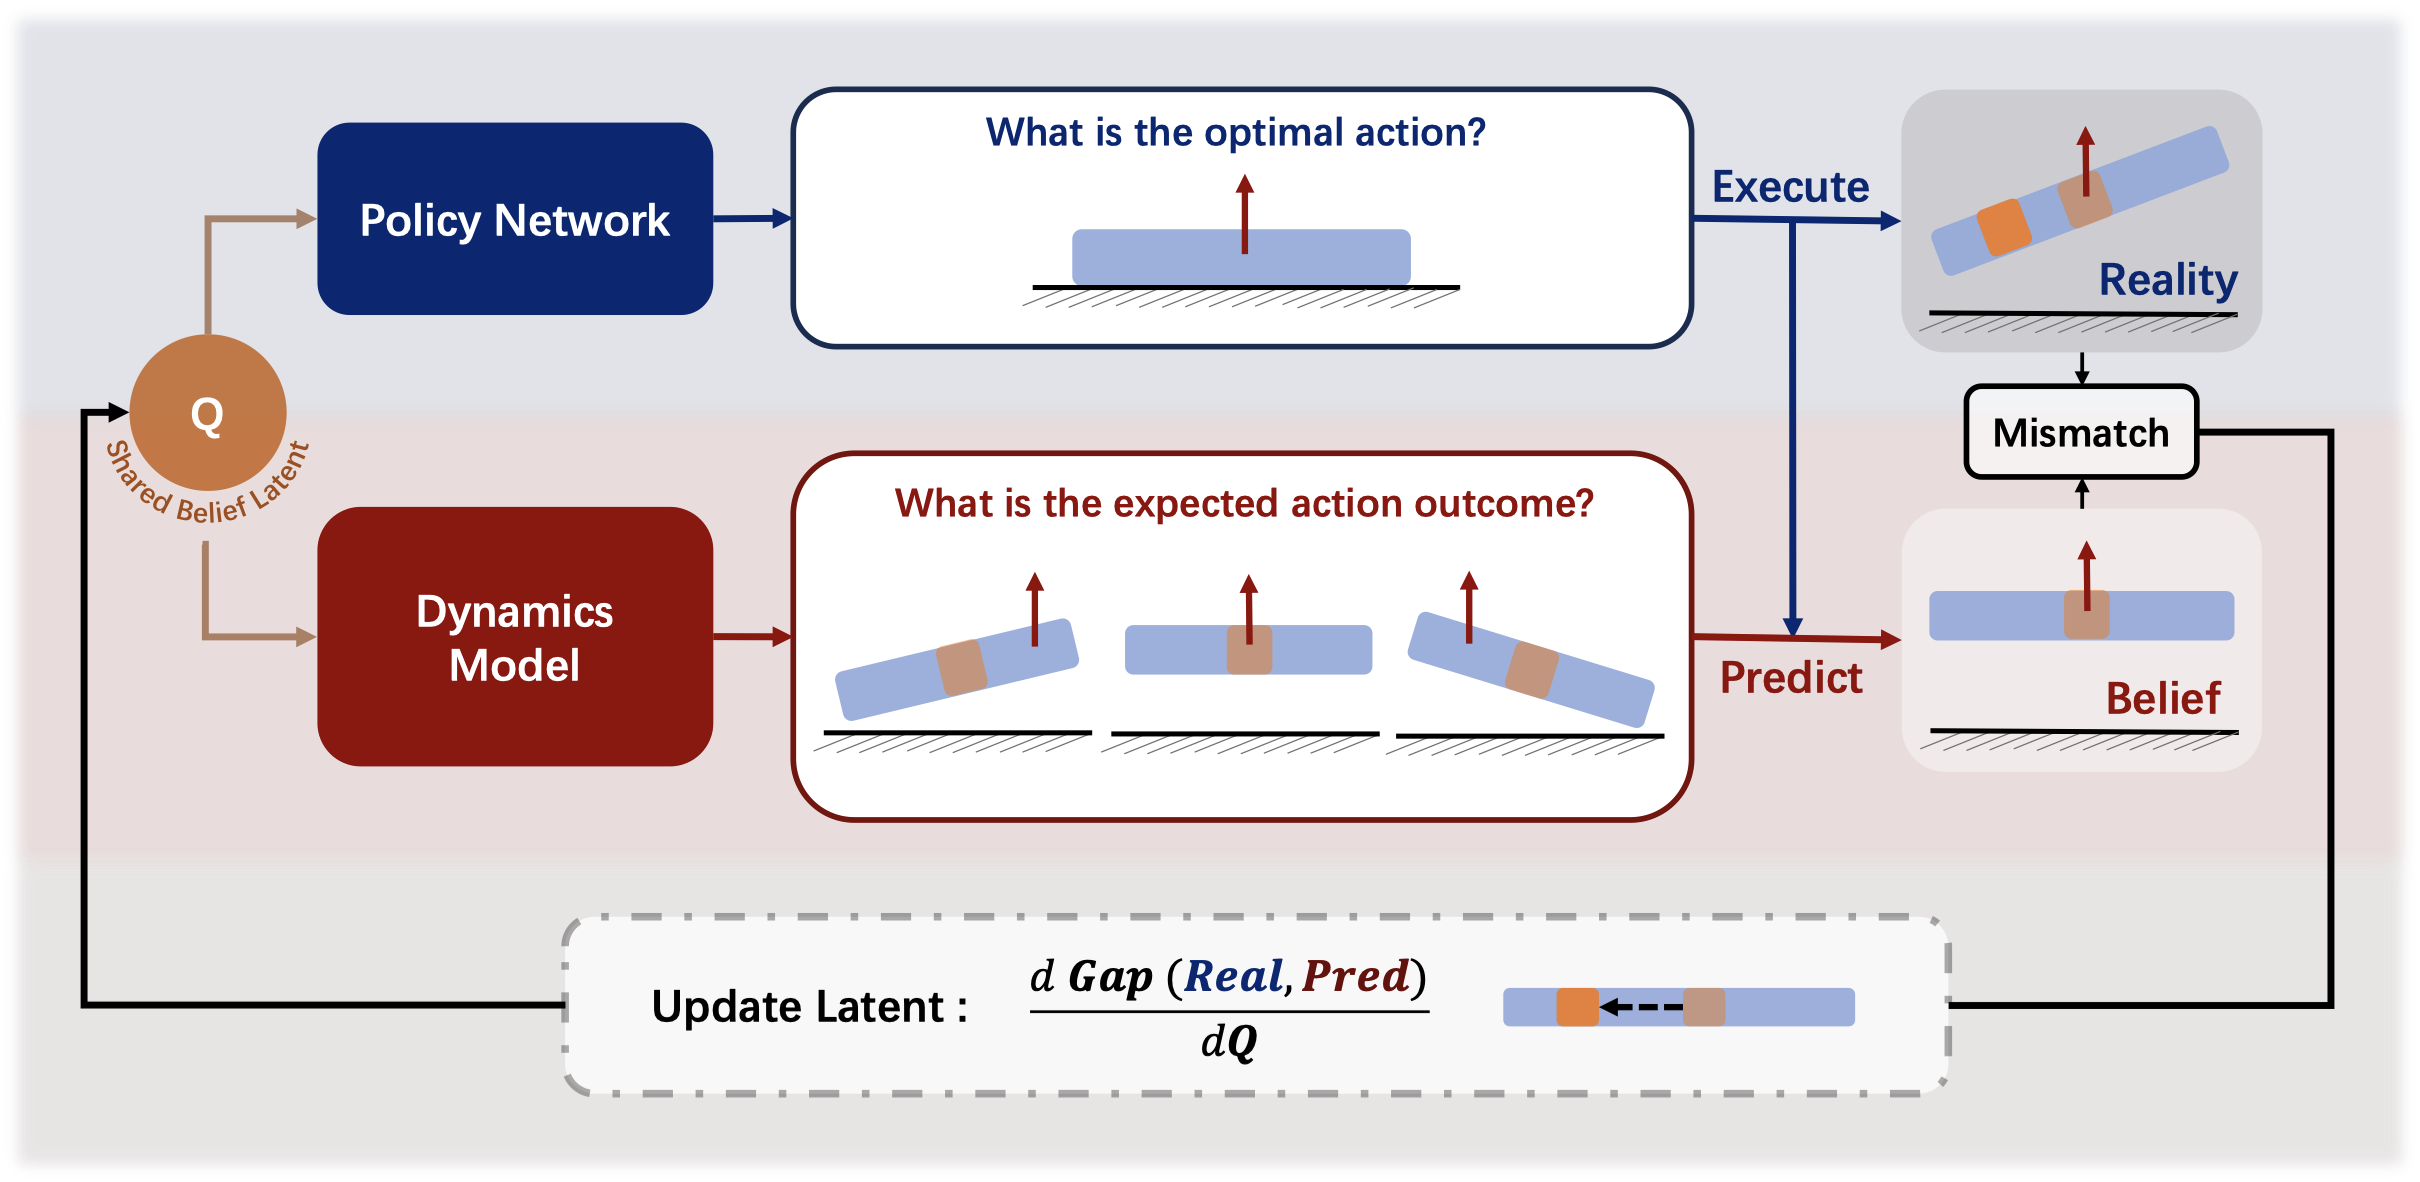
Scouting the Dynamics Gap: Test-Time Policy Adaptation via Action-Outcome Feedback
Yishu Li*, Liyuan Geng*, Xinyi Mao*, Amber Li, David Held
Conference on Robot Learning (CoRL) 2026
project page / arXiv

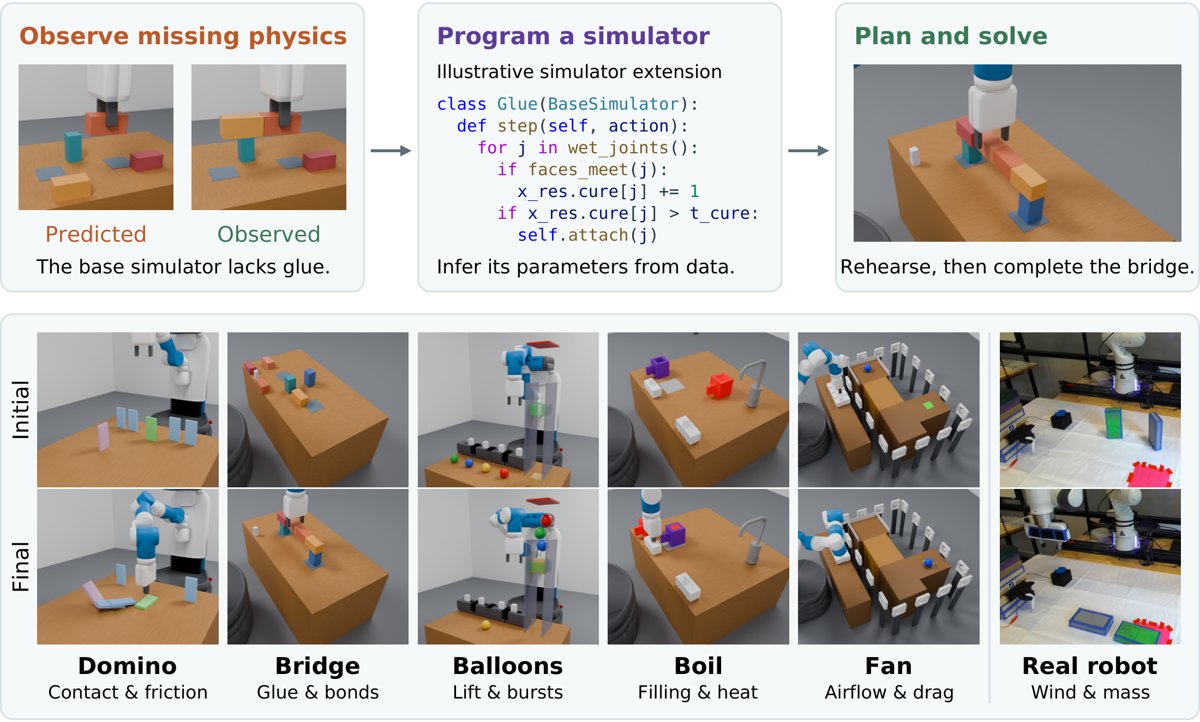
EMPIRIC: Experiment-Driven Learning of Residual World Models for Robot Planning
Yichao Liang, Amber Li, Dat Nguyen*, Emily Bunnapradist*, Michelangelo Naim*, Sreela Kodali*, Matteo Merler, Bowen Li, Kiran Gopinathan, Yiyun Liu, Nikhil Pimpalkhare, Joshua B. Tenenbaum, Adrian Weller, Zenna Tavares, Tom Silver†, Kevin Ellis†
arXiv preprint 2026
project page / arXiv / code

Planning from Point Clouds over Continuous Actions for Multi-object Rearrangement
Kallol Saha*, Amber Li*, Ángela Rodriguez-Izquierdo*, Lifan Yu, Ben Eisner, Maxim Likhachev, David Held
Conference on Robot Learning (CoRL) 2025 (Oral presentation, Top 5.7%)
project page / arXiv

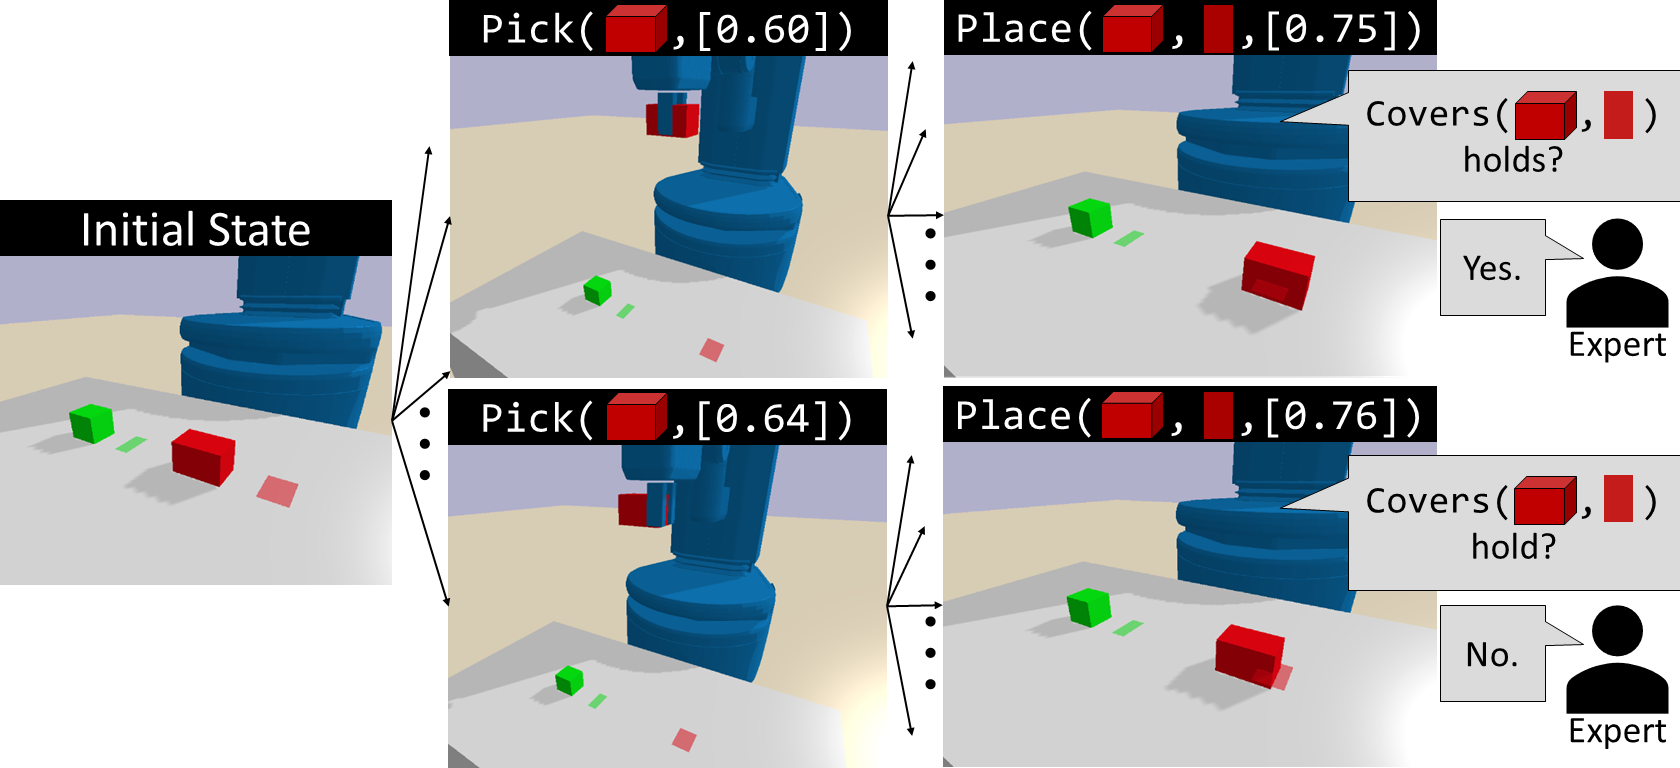
Embodied Active Learning of Relational State Abstractions for Bilevel Planning
Amber Li*, Tom Silver
Conference on Lifelong Learning Agents (CoLLAs) 2023 (Oral presentation, Top 12)
presentation / arXiv / code


Thanks to Jon Barron for the website template: original source code.